MorphIK: Morphology-Conditioned Neural Inverse Kinematics for Unknown Robots
arXiv:2609.29908,
doi: 10.48550/arXiv.2609.29908
- Sep 2026
Associated documents :


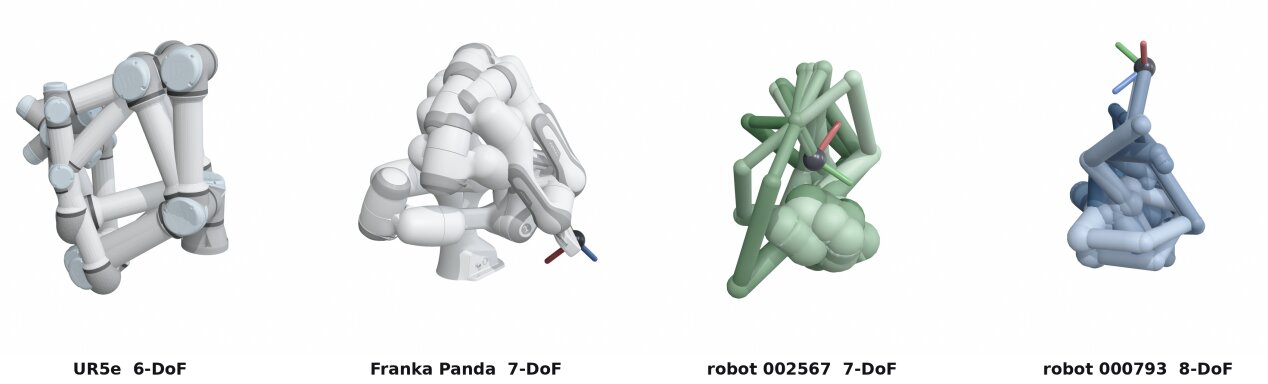
Neural models can learn to generate various solutions to the inverse kinematics problem from data, but are usually limited to a single robot. We present MorphIK, a flow-matching model that solves inverse kinematics for revolute-joint-based kinematic chains it has never seen during training. The model uses a transformer architecture to encode the robot's morphology along with the target pose. This encoding then conditions a flow-matching head that generates poses from noise. Trained on purely synthetic data from procedurally generated robots, the model reaches a precision of about 5 cm on unseen real-world robots with 6 to 9 Degrees of Freedom. For higher precision, the model serves as an excellent Prior for further optimization algorithms, reducing error to less than 1 cm after a single step of Damped Least Squares optimization and to sub-1 mm error after 3 steps in most cases. Building on flow matching's generative capabilities to produce highly diverse outputs, our model can efficiently sample the robot's null space, providing a wide variety of configurations for the same pose. Thus, overall, MorphIK allows learning and generalizing neural inverse kinematics for a multitude of known and unknown robots.
@Article{CHWW26,
 	 author =  {Clasmeier, Lennart and Habekost, Jan-Gerrit and Weber, Cornelius and Wermter, Stefan},
 	 title = {MorphIK: Morphology-Conditioned Neural Inverse Kinematics for Unknown Robots},
 	 booktitle = {}
 	 journal = {arXiv:2609.29908},
 	 editors = {}
 	 number = {}
 	 volume = {}
 	 pages = {}
 	 year = {2026},
 	 month = {Sep},
 	 publisher = {}
 	 doi = {10.48550/arXiv.2609.29908},
 	 url = {https://arxiv.org/abs/2609.29908},
 }